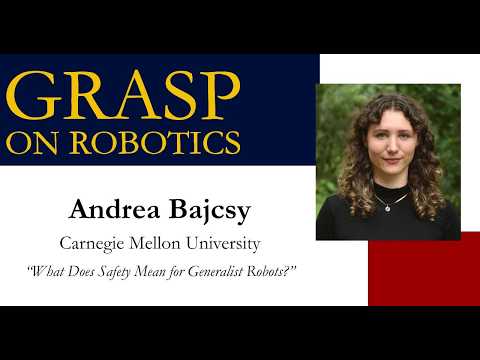
Fall 2026 GRASP on Robotics - Andrea Bajcsy, Carnegie Mellon University
“What Does Safety Mean for Generalist Robots?”
https://www.grasp.upenn.edu/events/fall-2026-grasp-on-robotics-andrea-bajcsy/
ABSTRACT
Robot safety is a nuanced concept. We commonly equate safety with collision-avoidance. However, when considering the possibility of generalist robots — one robot that can do “anything” — we need to expand our notion of safety. For example, a manipulator should understand when it is not confident about a requested task, that objects should be gently manipulated to prevent breaking or spilling, and that overheating items can cause burning or melting. However, designing robots that have such a nuanced safety understanding (and that can reliably generate appropriate actions) is an outstanding challenge. In this talk, I will describe my group’s work on systematically uniting modern machine learning models (such as large vision-language models and latent world models) with classical formulations of safety in the control literature to generalize safe robot decision-making to increasingly open world interactions. Throughout the talk, I will present experimental instantiations of these ideas in domains like vision-based robotic manipulation.
Presenter
https://www.cs.cmu.edu/~abajcsy/
Andrea Bajcsy is an Assistant Professor in the Robotics Institute at Carnegie Mellon University where she leads the Interactive and Trustworthy Robotics Lab (Intent Lab). She broadly works at the intersection of robotics, machine learning, control theory, and human-AI interaction. Prior to joining CMU, Andrea received her Ph.D. in Electrical Engineering & Computer Science from University of California, Berkeley in 2022. She is the recipient of the DARPA Young Faculty Award (2025), NSF CAREER Award (2025), Amazon Research Award (2025), Google Research Scholar Award (2024), Finalist for Best Paper Award of the IEEE RAS Technical Committee on Robot Control (2024), Rising Stars in EECS Award (2021), Honorable Mention for the T-RO Best Paper Award (2020), and the NSF Graduate Research Fellowship (2016).
https://www.youtube.com/watch?v=DN2pIV-eASA




 Seonglae Cho